Compact High Torque
Compact installation with high torque in limited space.
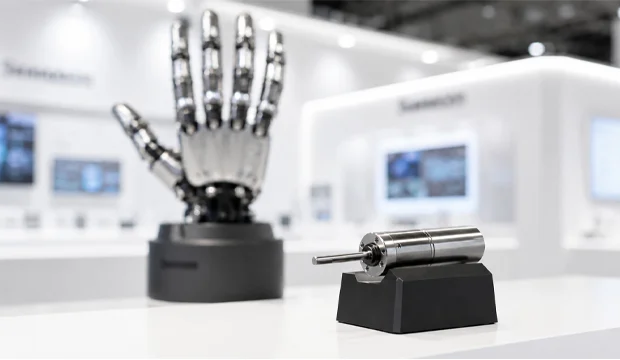
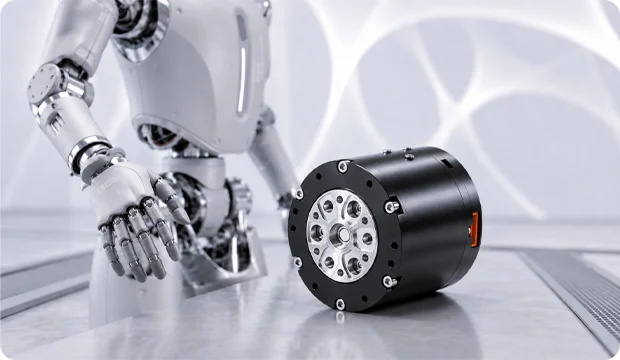
Humanoid robots use high-torque joints for major axes and compact servo solutions for wrists, fingers, and other space-limited mechanisms.
Engineering motion into limited space
Compact installation with high torque in limited space.
Smooth, accurate, and repeatable positioning across every cycle.
Lightweight design for distal joints and dexterous hands.
Optimized speed and reduction ratio for responsive motion.
Reliable performance through continuous and repeated motion cycles.
Custom shafts, mounting, and interfaces for seamless integration.
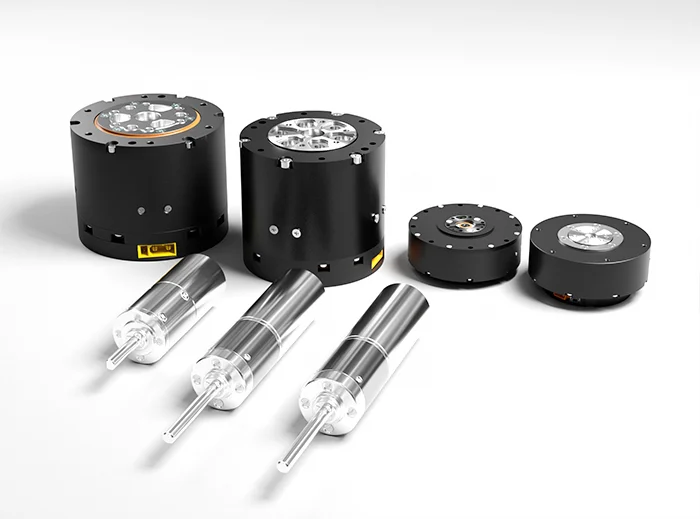
From precise finger movements to coordinated robot joints, ABASS provides a compact transmission solution for humanoid robots. We have PG series robot joint modules and QJS series dexterous hand modules, with applications in robot joints, human exoskeletons, robot arms, etc.
Connect with our expert engineers and project managers to get accurate guidance and support.