3D Model

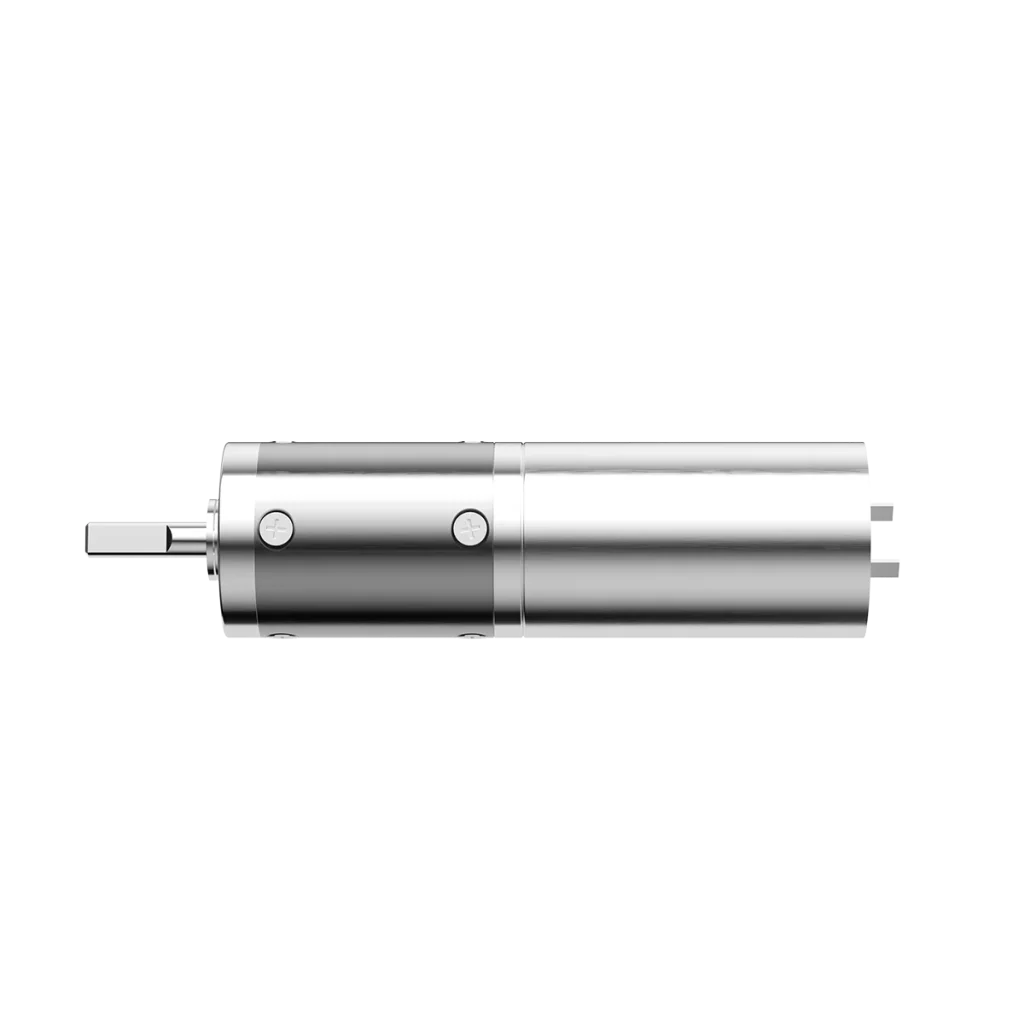
Product Image

SKU:
QJS 16
Category:
Robot Joint Module, Dexterous Hand Joint Module

Scene Diagram

Qsj12mm场景图 (1)
Qsj12mm场景图 (2)
Qsj12mm场景图 (3)
Qsj12mm场景图 (4)
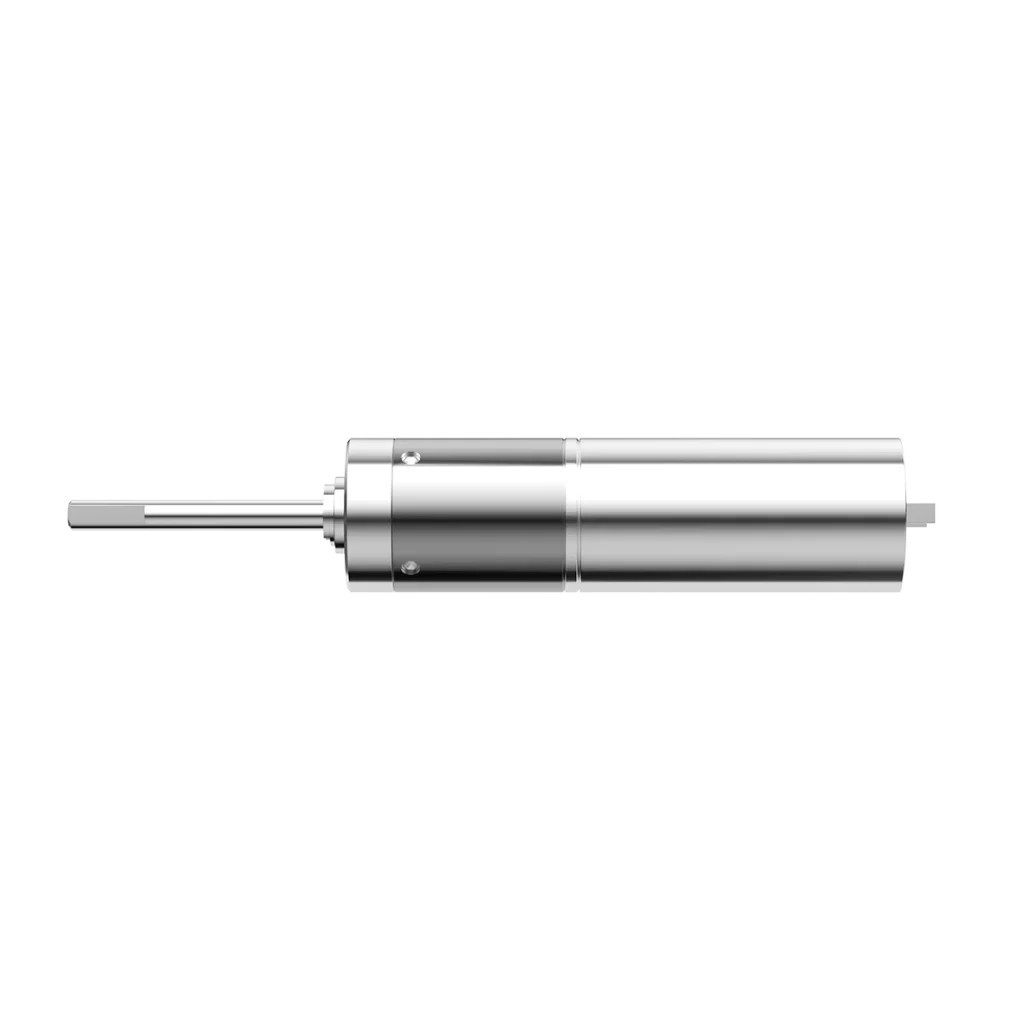
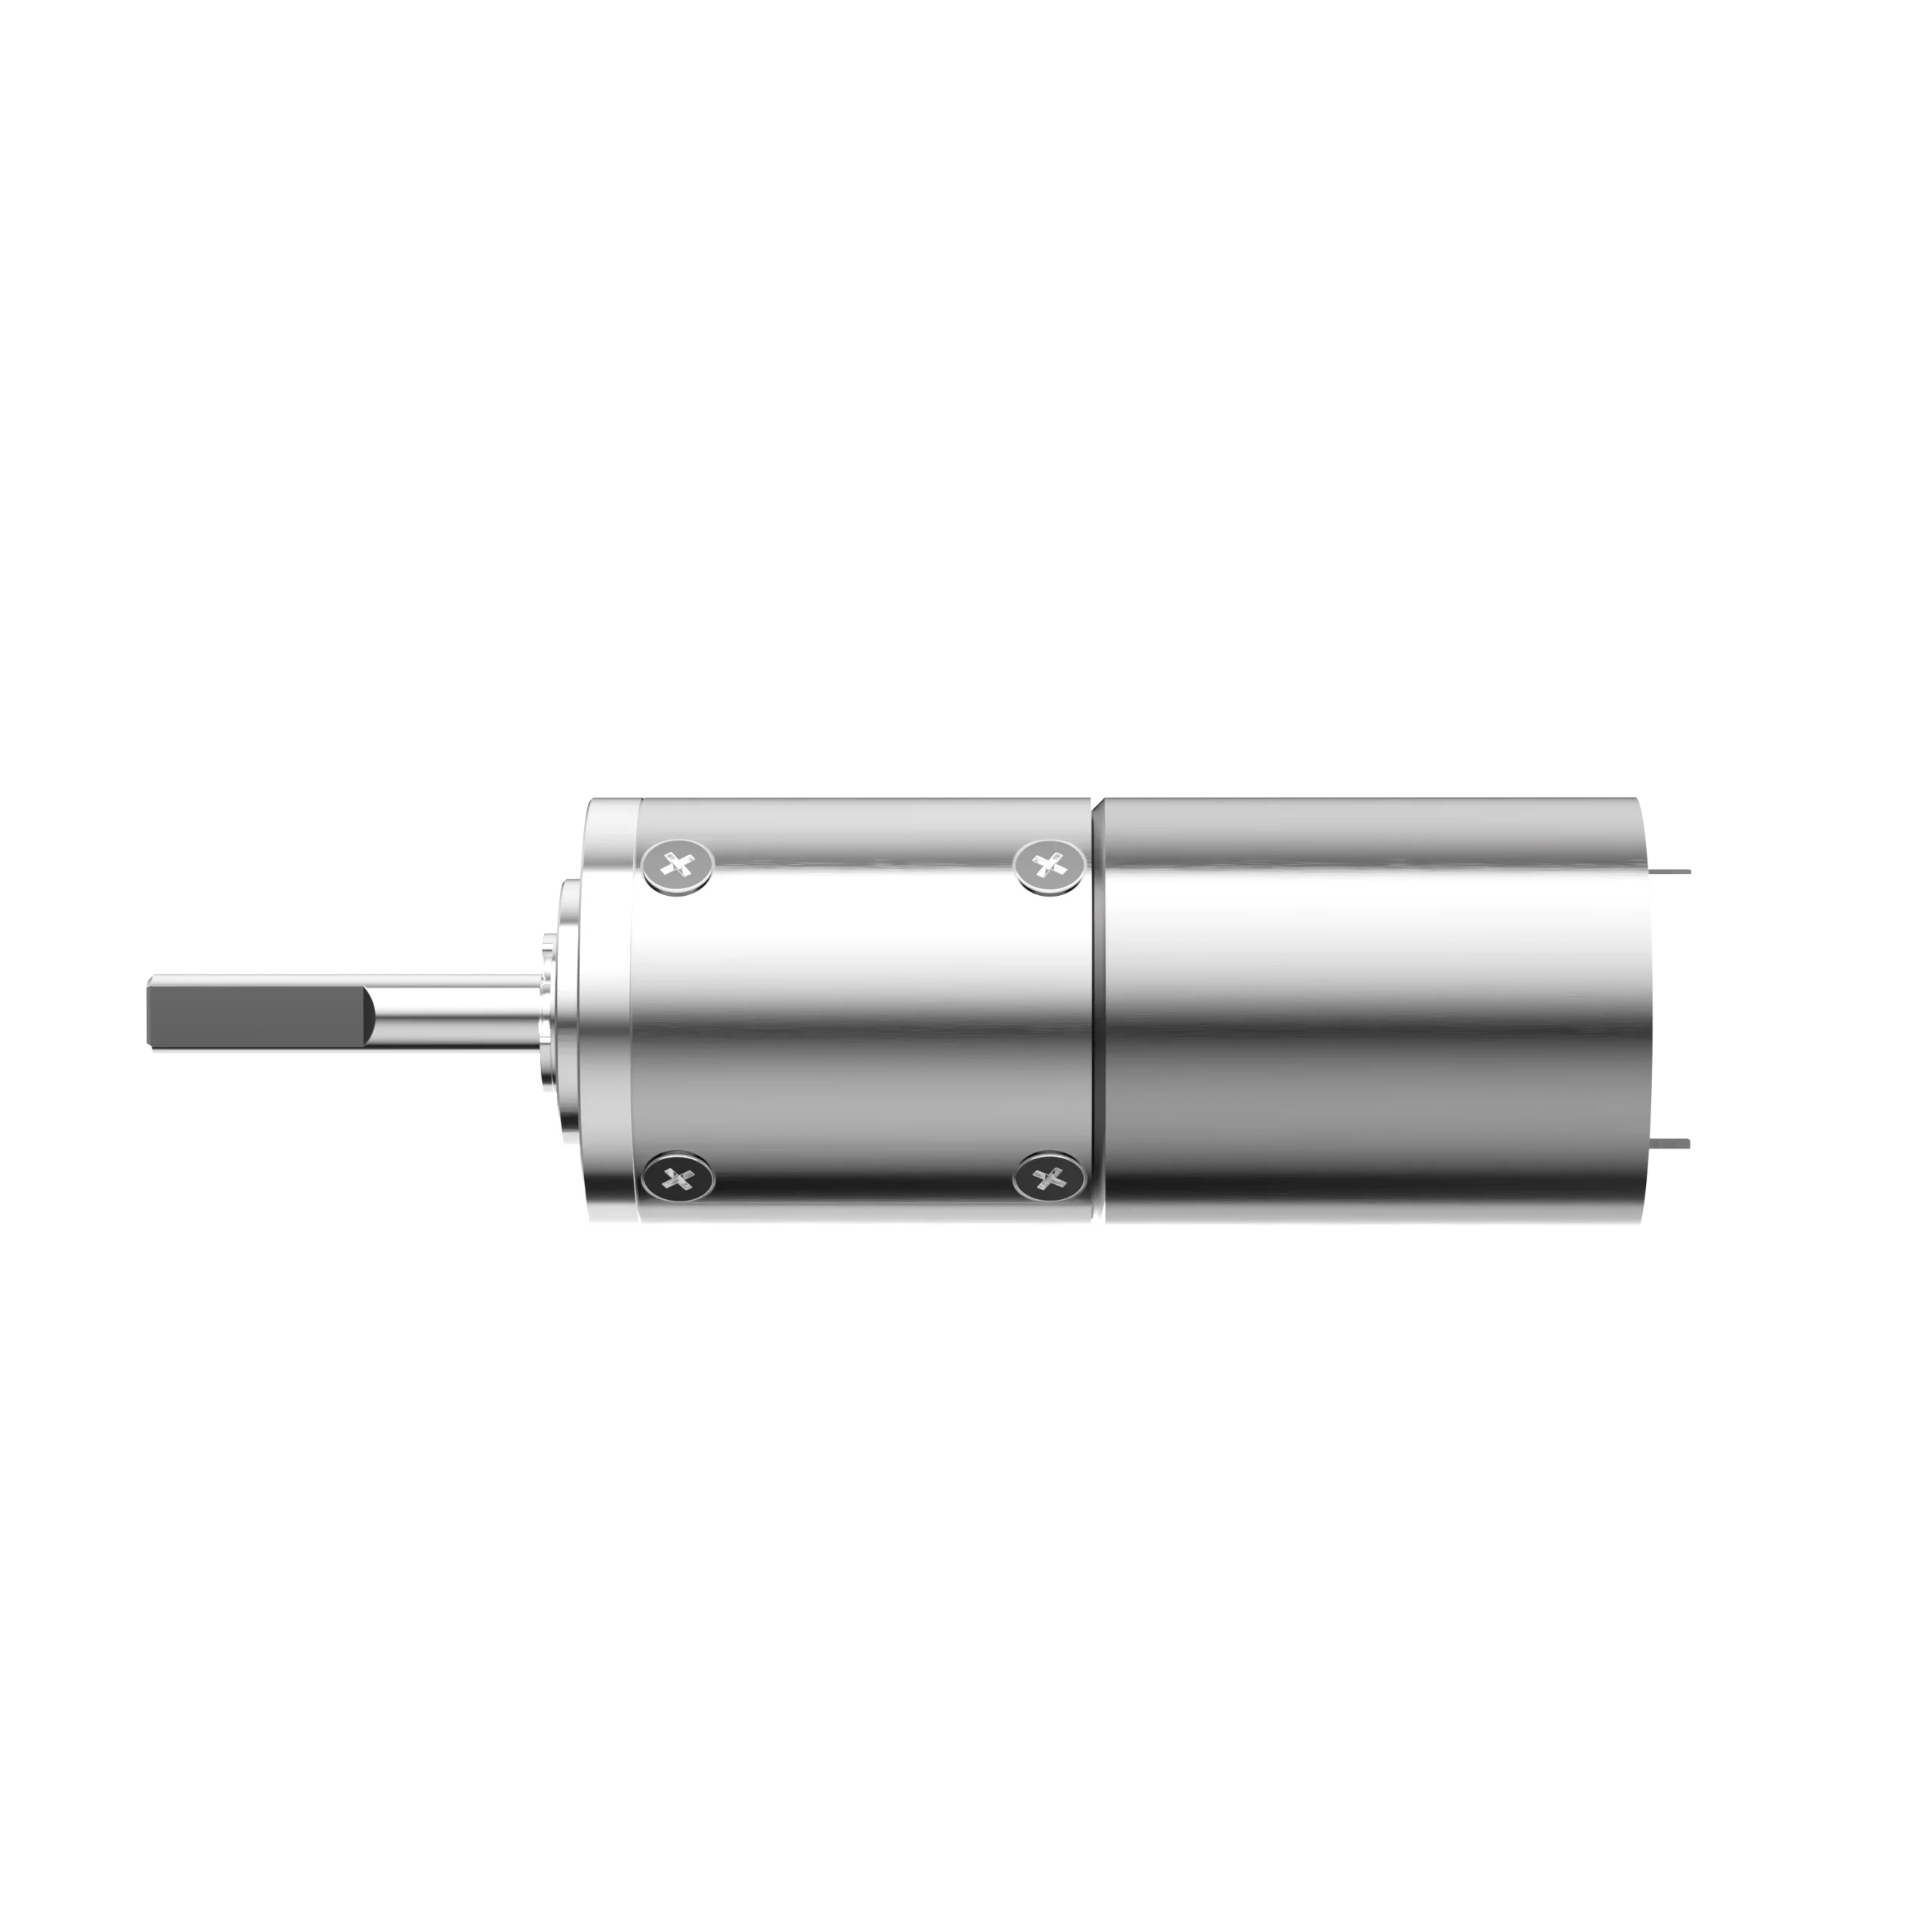
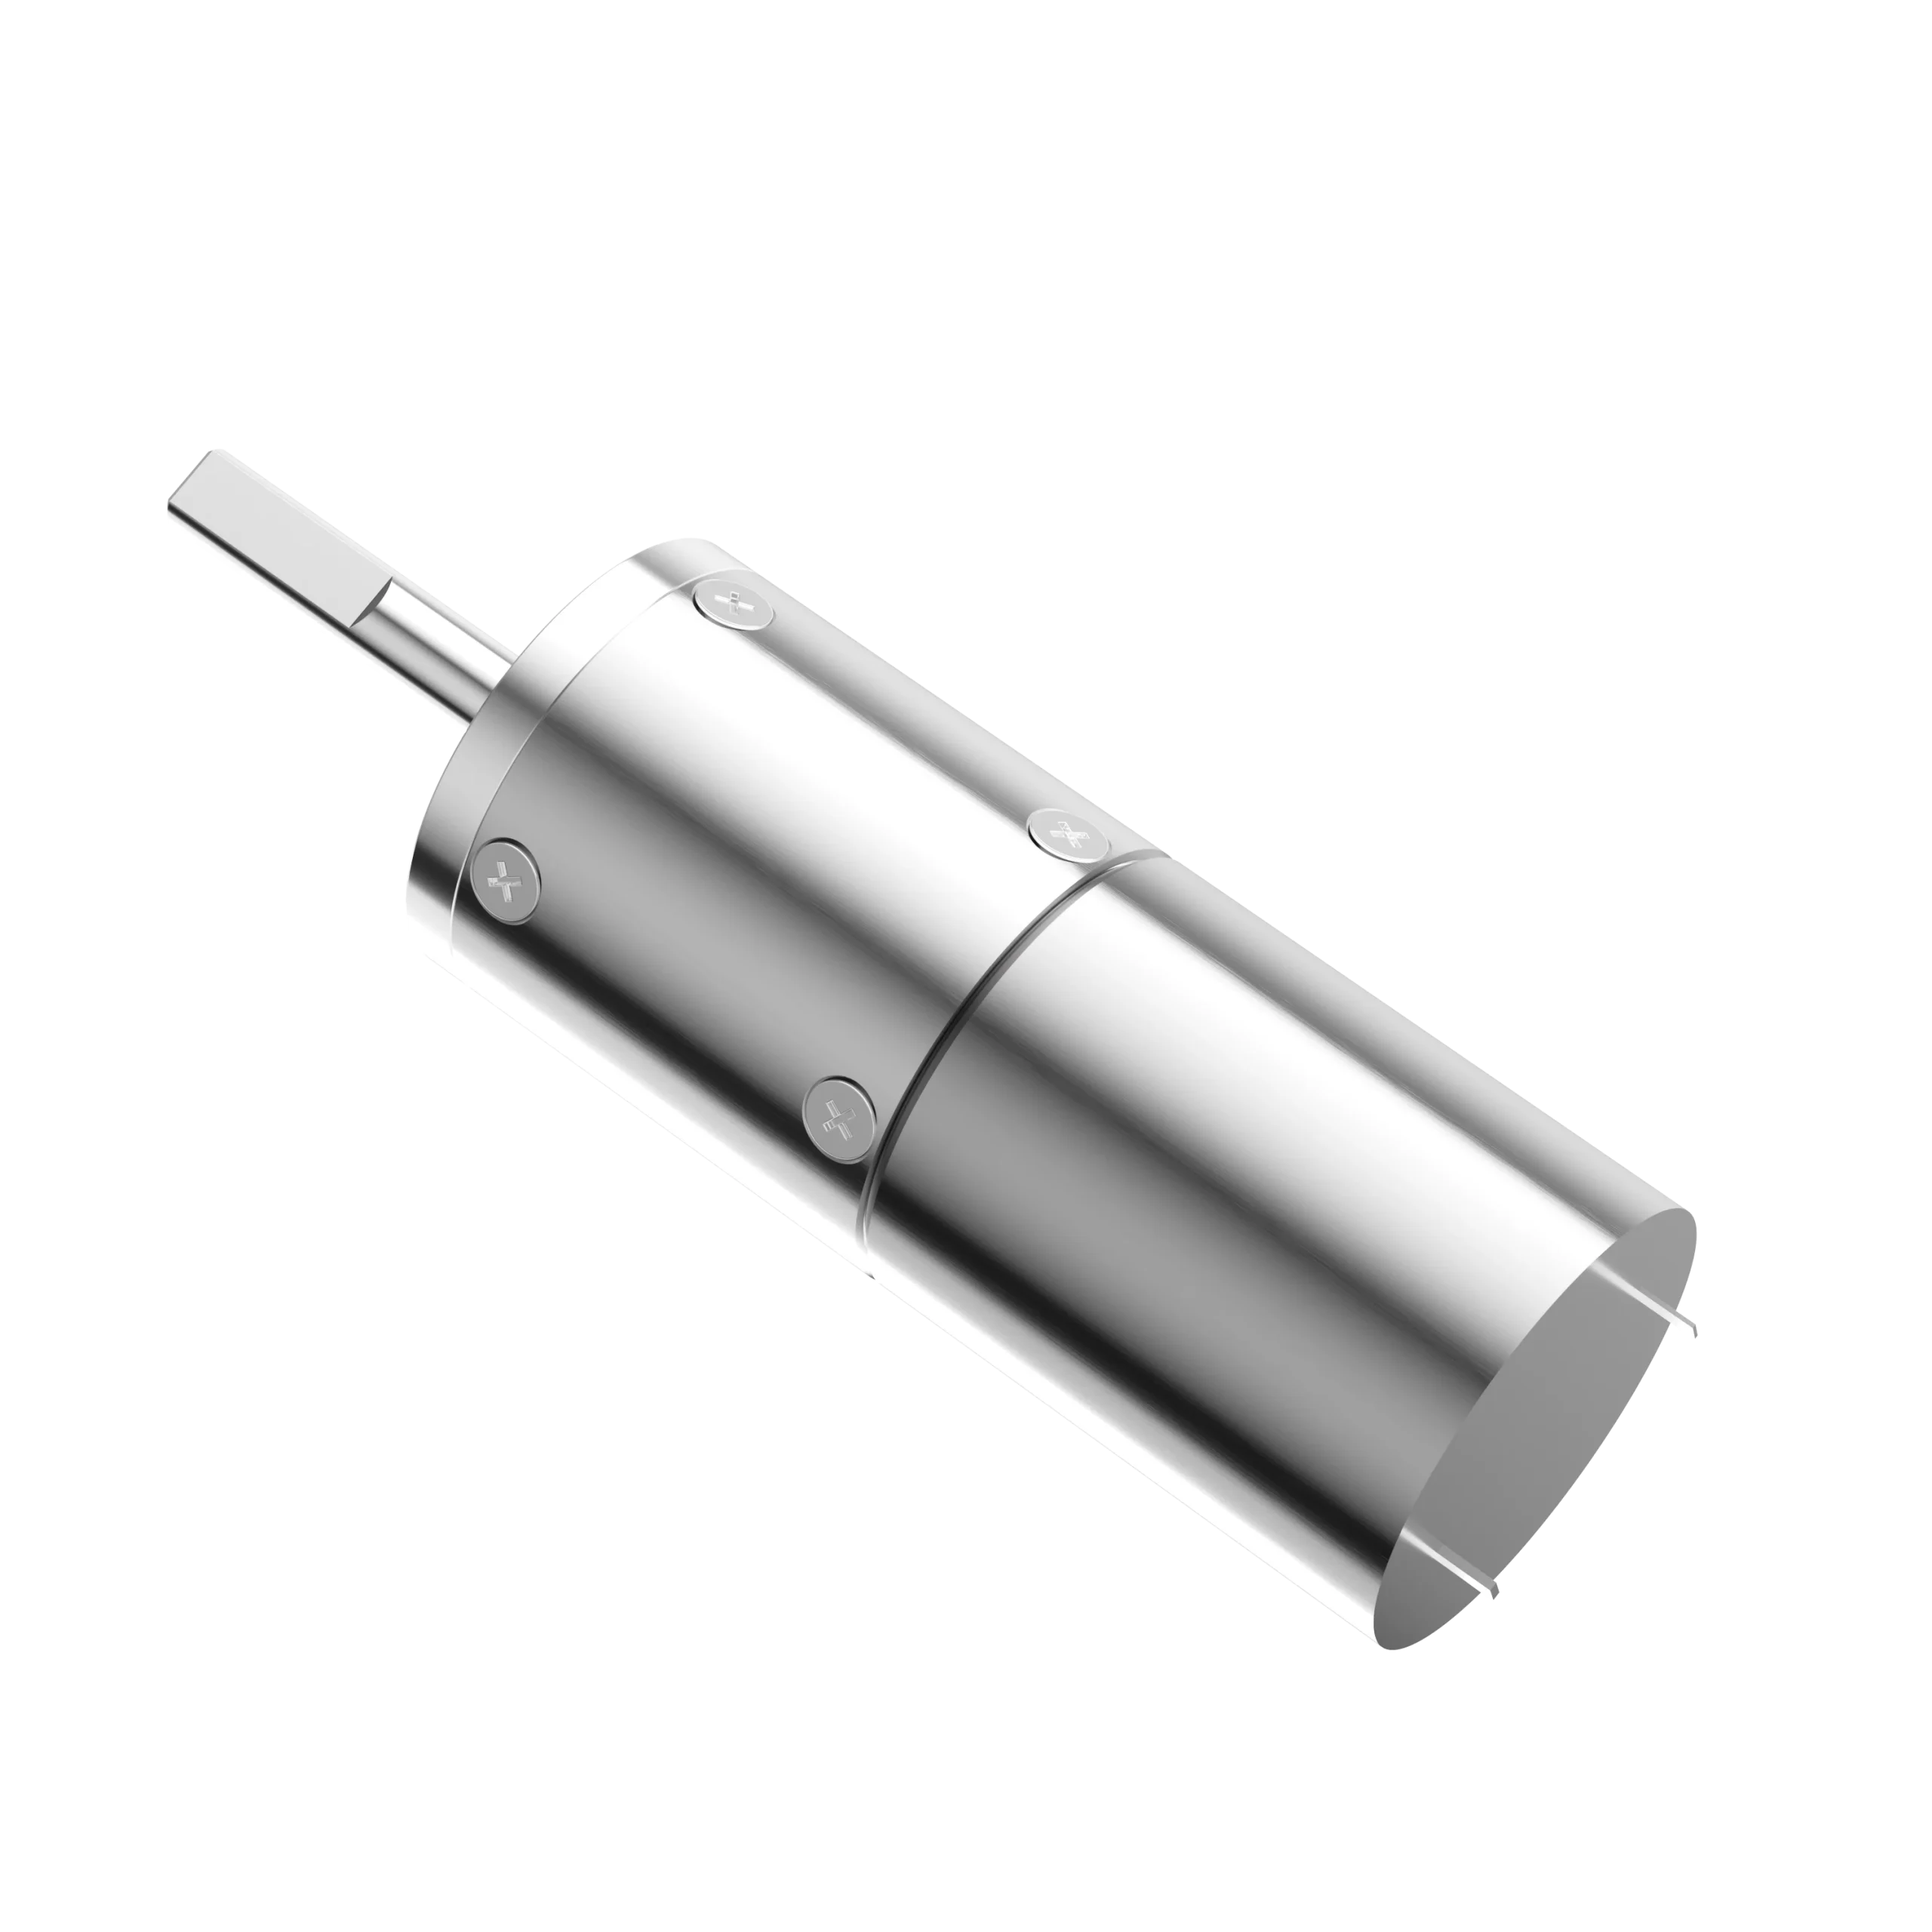
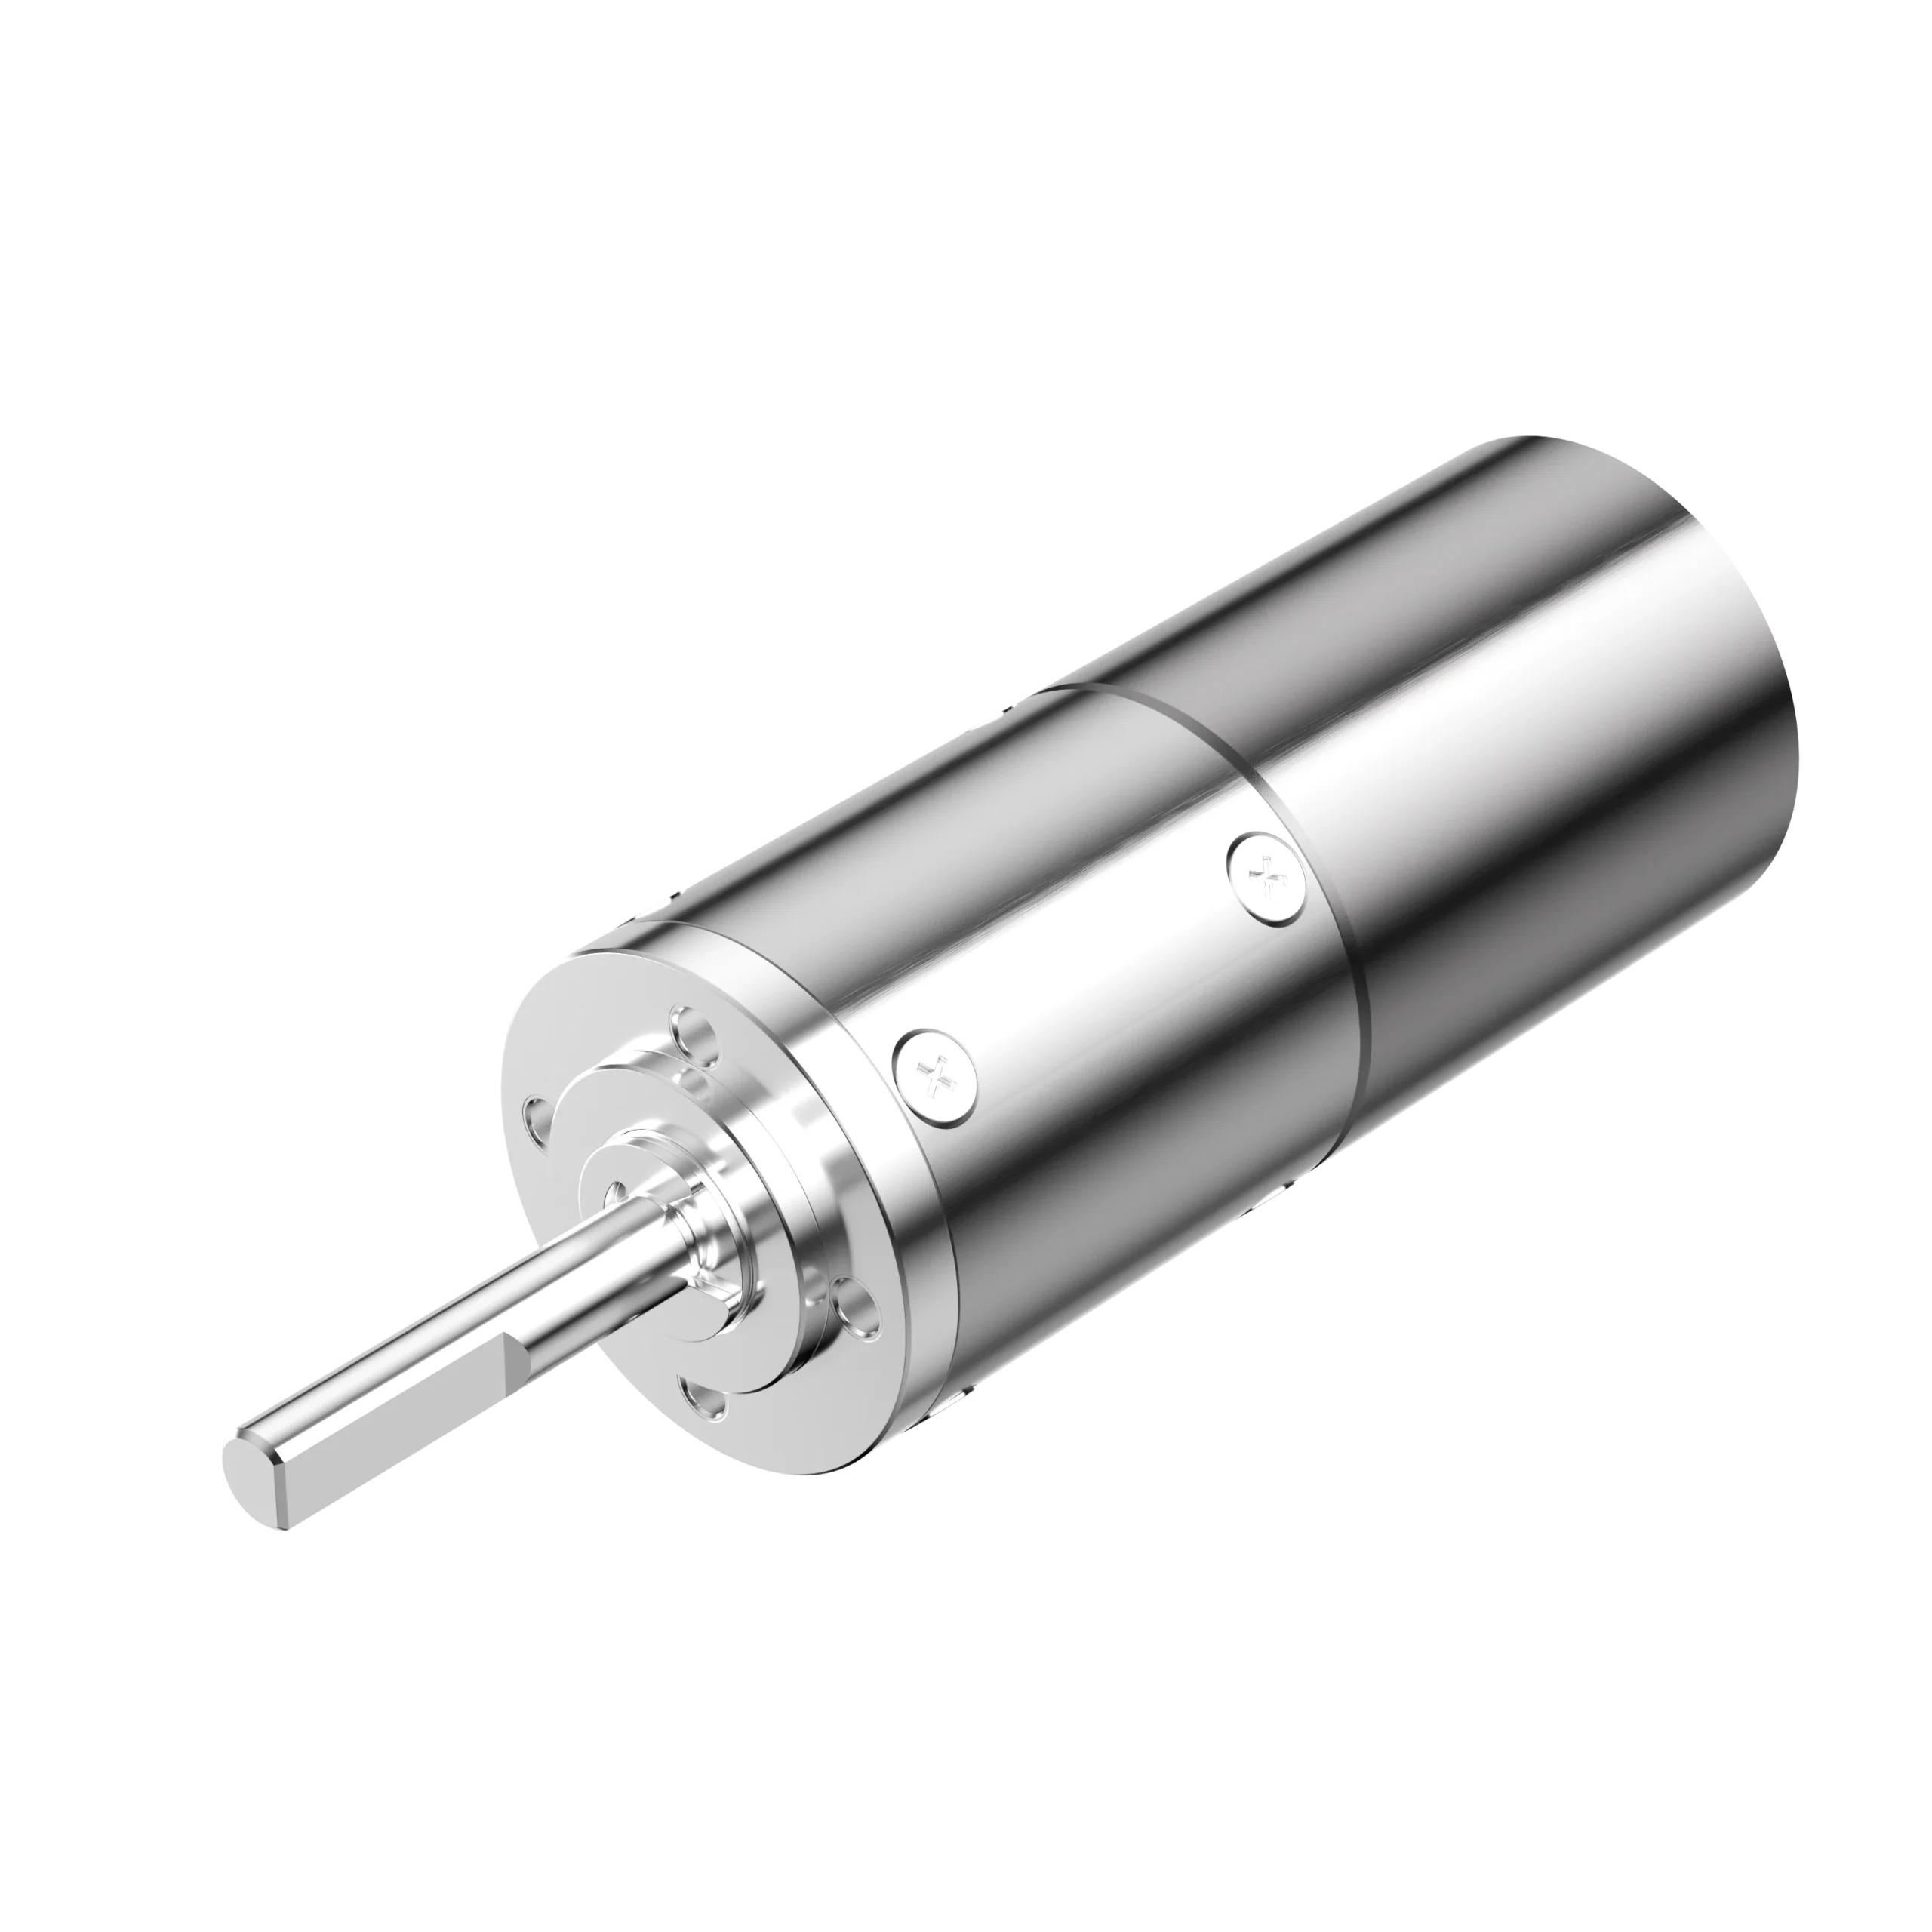
QJS 16mm Miniature Dexterous Hand Joint Module

QJS 16mm Miniature Dexterous Hand Joint Module features a 16 mm outer diameter, 1–4 stage planetary architecture, and up to 4 kgf·cm momentary torque. With 90% efficiency in the single-stage configuration and a robust metal construction, it delivers reliable motion performance in space-constrained applications.

  • 16mm Compact Form Factor
  • Up to 4 kgf·cm Momentary Torque
  • 1–4 Stage Flexible Configuration
  • 90% Single-Stage Efficiency
Parameter
QJS 16 mm
Number of Gear Stages 1 2 3 4
Reduction Ratio 4 16, 24, 36 64, 96, 144, 216 256, 384, 576, 864, 1296
Gear Length (mm) 16 18.4 20.1 23.5
Max. Allowable Continuous Torque (kgf·cm) 2 1.2 2 2.8
Max. Allowable Momentary Torque (kgf·cm) 1.5 2.2 3 4
Efficiency (%) 90 81 73 65
Motor Length Total motor length determined by specified motor
Outer Diameter 16 mm
Gear Structure Planetary
Output Shaft Material Stainless Steel
Output Shaft Bearing Type Roller Bearing
Gear Material Machined Metal Gear
Housing Material Metal
Operating Humidity 20%–85% RH
Operating Temperature -25°C–+100°C
Customization Designed and manufactured according to customer requirements
Recommended Industries